Framework
How Should Warehouse Automation ROI Be Modeled?
Warehouse robotics ROI depends on labor cost removal and sustained utilization. The Robotics ROI Model , developed by Autonomy Bridge , models the full economic chain from labor baseline through capital payback across six linked components.
Evidence scope: these pages distinguish analytical interpretations, illustrative calculations and source accounts. Unsupported numerical benchmarks identified in the review have been withdrawn. Retained case narratives are source accounts, not independently verified client outcomes; they have not been relabelled as hypothetical. Internal framework links provide context, not external substantiation. Read the page-specific assumptions and limitations and the Methodology.
The Robotics ROI Model is a proprietary economic framework developed by Autonomy Bridge that links six sequential components , labor baseline, robot productivity, fleet sizing, utilization, integration cost, and capital payback , into a single analytical chain for evaluating warehouse automation investments. The model determines whether a robotics deployment will recover its capital under real operational conditions, not theoretical peak performance. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Warehouse automation ROI depends on two primary forces: how much labor cost the robotics system removes, and how consistently that system is utilized across the operating year. Automation converts flexible labor capacity into fixed infrastructure. Economic outcomes depend less on robot speed and more on whether real facility demand keeps installed capacity active enough to recover capital.
This framework targets operators evaluating automation deployment in mid-size fulfillment warehouses, including third-party logistics (3PL) providers and dedicated e-commerce fulfillment operators.
Framework hub: All Autonomy Bridge Frameworks →
Problem the Framework Solves
Most warehouse robotics ROI models fail because they treat automation as a technology purchase rather than a capacity economics decision. Vendors present productivity benchmarks under controlled conditions. Operators apply those benchmarks to their peak demand scenarios. The resulting business cases systematically overestimate savings and underestimate risk.
The Robotics ROI Model corrects this by requiring operators to validate every layer of the economic chain before committing capital.
Why Existing Approaches Fail
Robotics deployments fail economically when assumptions diverge from operational reality.
Underutilization , Robotic capacity sits idle during large portions of the operating year. A fleet sized for peak demand delivers low utilization at average demand, spreading capital cost across fewer orders.
Overestimated labor savings , Business cases assume labor elimination that operational workflows cannot achieve. Most robotic systems remove travel time, not handling time.
Downstream bottlenecks , Packing or sortation processes cap facility throughput before robot capacity is exhausted. See: Pick Station Throughput →
Integration complexity , System orchestration issues reduce realized productivity below modeled levels. See: Integration Cost →
Operational rigidity , Automation architectures constrain the warehouse’s ability to adapt to new customer SKU profiles or order structures.
Key Finding (Autonomy Bridge, 2026): Automation failures rarely occur because robots do not work. They occur because utilization assumptions prove unrealistic. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Framework Overview
The Robotics ROI Model structures warehouse automation economics as a layered chain. Each component determines the viability of the next. A weakness in any single layer undermines the entire economic case.
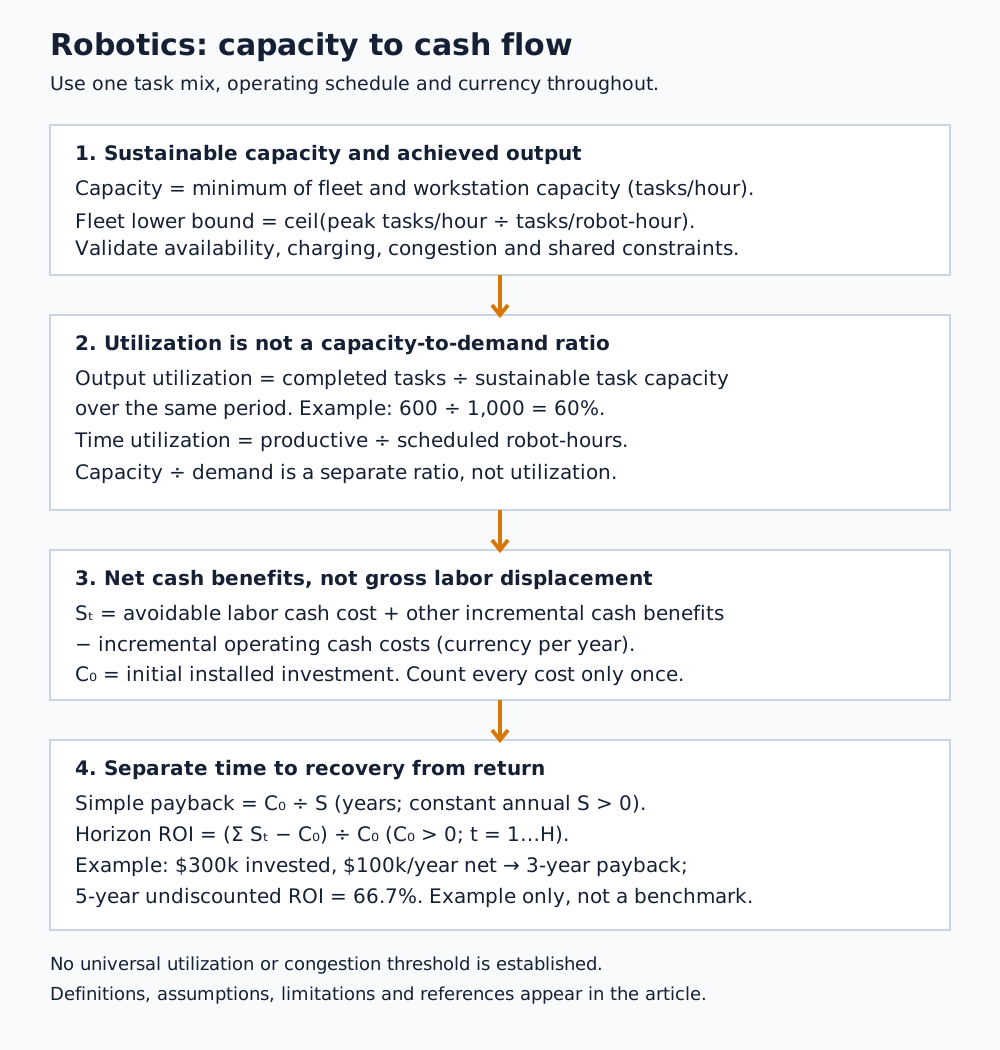
Framework chain:
Labor baseline
↓
Robot productivity
↓
Fleet sizing
↓
Utilization
↓
Integration cost
↓
Capital payback
- Labor economics determine potential savings.
- Robot productivity determines achievable throughput.
- Fleet sizing determines installed capacity.
- Utilization determines capital recovery speed.
- Integration cost determines total capital exposure.
- Payback determines whether the investment is economically justified.
Component 1: Labor Baseline Model
Automation economics begin with the labor baseline. A warehouse must identify which labor tasks drive cost and which tasks robotics can realistically remove. Most warehouse labor is not item handling , it is travel time between pick locations.
Key Finding (Autonomy Bridge, 2026): Robotics rarely eliminates all picking labor. Most systems remove travel time, not handling time. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Warehouse workflows include storage retrieval, inter-location travel, item handling, order consolidation, packing, and internal transport.
In manual operations, worker time allocates as:
Tworker = Ttravel + Thandling + Twaiting
Where:
Tworker= total labor time per order lineTtravel= time spent walking or transporting itemsThandling= time spent physically picking itemsTwaiting= time lost due to congestion or workflow delays
Autonomous Mobile Robots (AMRs) and goods-to-person (G2P) systems primarily target Ttravel. If handling time dominates the workflow, robotics removes a smaller share of total labor cost.
Labor cost baseline:
Clabor = Lworkers × Wrate × Hhours
Where:
Lworkers= number of workersWrate= fully burdened wage rate, in currency per worker-hour (including benefits and overhead)Hhours= scheduled hours per worker in the same year; do not multiply total team hours by worker count again
Automation only affects the share of labor tied to tasks robots can substitute. If labor substitution is limited, automation savings are capped. See: Removable Labor Share →
Machine-readable logic:
- If travel time represents the majority of pick labor → goods-to-person or AMR systems can remove a large share of labor cost.
- If handling time dominates the workflow → robotics will remove a smaller share of labor cost.
Component 2: Robot Productivity Model
Robot productivity determines the throughput potential of the system. Robotic productivity does not operate independently , pick stations, system orchestration software, and workflow bottlenecks all constrain realized output.
Key Finding (Autonomy Bridge, 2026): Robot fleets often appear productive in isolation but are limited by human workstations at the point of order fulfillment. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Robot productivity:
Probot = Tasks / Cycle Time
Where:
Probot= robot productivity rateTasks= completed actions per cycle, measured in tasks per robot-cycleCycle Time= elapsed hours per robot-cycle, including the modeled handling and waiting time; Probot is tasks per robot-hour
Total system throughput is constrained by the bottleneck:
Tsystem = min(Trobot, Tstation)
Where:
Tsystem= sustainable system capacity, in tasks per hourTrobot= sustainable fleet capacity in tasks per hour (Nrobots × Probot before shared constraints)Tstation= sustainable combined workstation capacity in tasks per hour
If robots deliver work faster than stations can process it, robots queue and idle. Adding robots without adding station capacity produces no throughput gain. See: Pick Station Throughput →
Machine-readable logic:
- If robot throughput exceeds station capacity → robots will queue and system productivity stops increasing.
- If station capacity increases → robot productivity gains become usable throughput.
Component 3: Fleet Sizing Logic
Operators size robot fleets to handle peak operational demand. Average demand is lower than peak demand in most warehouses , particularly in e-commerce and 3PL environments with seasonal volume concentration. This gap creates utilization risk.
Key Finding (Autonomy Bridge, 2026): Automation capacity is built for the busiest period of the year. Average demand across the remaining months determines whether the investment pays back. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Fleet capacity must satisfy:
Tsystem ≥ Dpeak
Fleet size:
Nrobots = ceil(Dpeak / Probot)
Where Dpeak is peak demand in tasks per hour and Probot is tasks per robot-hour over the same operating conditions. Nrobots is a whole-robot lower bound, rounded up; station, charging, availability and congestion constraints still need validation. For a hypothetical 120 tasks/hour and 25 tasks/robot-hour, ceil(120/25) = 5 robots before those constraints.
Output utilization and demand loading are distinct:
U = Qactual / Qcapacity
Load = Davg / Tsystem
Rcapacity = Tsystem / Davg
Qactual is completed tasks and Qcapacity is sustainable task capacity over the same specified period, task mix and work schedule. U is dimensionless; multiply by 100 for percent. Davg and Tsystem are both tasks per hour. Load is a planning proxy for utilization only if demand is served; Rcapacity is a capacity-to-demand ratio, not utilization. A zero capacity makes U undefined; zero demand makes Rcapacity undefined. Investigate inconsistent measurement if measured output exceeds the stated sustainable capacity.
Hypothetical example: 600 tasks completed in an hour against capacity of 1,000 tasks in that hour gives U = 0.60 (60%). With demand of 600 tasks/hour, Load = 0.60 and Rcapacity = 1.67. Neither ratio is a profitability threshold.
Definition reference: the Federal Reserve capacity-utilization notes use output divided by capacity and define capacity on a sustainable operating schedule. This is a definition reference, not evidence for a robotics performance benchmark.
Machine-readable logic:
- If peak demand significantly exceeds average demand → robot utilization will be low.
- If utilization declines → capital recovery slows and payback period extends.
Component 4: Utilization Threshold Concept
Utilization determines how effectively capital investment generates returns. Robotics systems carry fixed costs regardless of operating volume. Low utilization spreads those fixed costs across fewer orders, eroding cost-per-unit economics.
Key Finding (Autonomy Bridge, 2026): A robotics system can improve peak throughput and still fail economically due to underutilization at average demand. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Automation shifts cost structure from variable to fixed:
| Model | Cost Structure |
|---|---|
| Manual | Baseline operating cash cost over a stated horizon, in currency |
| Automation | Initial installed investment plus operating cash costs over that same horizon, in currency |
Model inputs (a dependency list, not an ROI calculation):
ROI_H depends on C0, annual net cash flows, and horizon H
Where:
Ccapex= initial automation capital cost, included in C0Clabor= annual labor cost baseline, in currency per yearU= utilizationV= annual order volume, in orders per yearT= system throughput capacity, in tasks per hour
Annual labor savings depend on system utilization:
Savingsannual = f(U, Clabor, Lsub)
This is a dependency statement, not a numerical savings formula. Where Lsub = share of baseline labor cost that can actually be avoided, not simply redeployed. Do not multiply realized savings by utilization again. See: Removable Labor Share →
Machine-readable logic:
- Higher utilization can improve savings only when additional output creates avoidable cash costs or other incremental cash benefits; it is not a guarantee.
- If utilization declines → capital recovery slows.
- Evaluate the initial installed investment (C0, currency units) against incremental net cash flows over a stated horizon H (years). Define utilization using throughput and capacity over the same period. A break-even utilization or volume can be solved only if the project-specific cash-flow function supports one; it is not a universal operating threshold. Annual capital cost divided by savings per unit has units of units per year, not a utilization percentage, and does not by itself establish project payback.
Component 5: Integration Cost Structure
Automation deployment requires integration across software, infrastructure, and workflows. These costs are systematically underestimated in ROI models. Integration complexity materially changes payback outcomes.
Key Finding (Autonomy Bridge, 2026): Integration costs must be estimated explicitly for the deployment; no general ratio to hardware cost is established here. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Integration cost categories include:
- Warehouse management system integration
- Warehouse control system deployment
- Robot fleet orchestration software
- Network infrastructure upgrades
- Safety systems
- Facility layout modifications
- Operational ramp disruption
Total automation investment:
Ccapex = Chardware + Cintegration + Cfacility
Where:
Chardware= robots and equipmentCintegration= software and system integrationCfacility= layout modifications and infrastructure
Operational ramp reduces throughput temporarily:
Tramp < Tsteady
Where:
Tramp= throughput during deployment phaseTsteady= steady-state throughput
See: Integration Cost → · Ramp Risk →
Machine-readable logic:
- If integration complexity increases → deployment cost increases.
- If deployment disrupts operations → short-term productivity declines.
Component 6: Payback Model
Payback depends on whether labor savings generated by automation exceed capital cost over the system life. Labor cost acts as a multiplier in the automation equation. High labor cost environments support faster capital recovery.
Key Finding (Autonomy Bridge, 2026): Automation does not reduce all labor. It reduces the portion of labor tied to the automated task. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Use net cash flows, a stated horizon and a consistent currency:
S_t = avoidable labor cash cost_t + other incremental cash benefits_t
      - incremental operating cash costs_t
Simple payback = C0 / S                         (years, constant S > 0)
ROI_H = (sum(S_t, t=1..H) - C0) / C0           (dimensionless, C0 > 0)
C0 is the initial installed investment, including hardware, integration, facility changes and initial ramp costs not already counted in S_t. S_t is net cash benefit for year t after incremental maintenance, software, energy and support costs. Count each cost once. Labor redeployment is not automatically a cash saving. The same currency and price basis must be used throughout.
Simple payback uses constant annual net cash benefit S (currency/year). If annual cash flows vary, accumulate S_t until the initial investment is recovered; if it is never recovered within H years, report “not recovered within the modeled horizon.” Fractional-year interpolation requires an explicit assumption about timing within that year. Zero or negative constant S has no finite simple payback. Horizon ROI is an undiscounted net return over H years, not an annual return or IRR; multiply by 100 for percent. These simplified measures omit time value of money and assume no terminal value or tax effects unless explicitly added to the cash-flow model. Use discounted analysis for decisions requiring those effects.
Hypothetical example: C0 = $300,000, annual avoidable labor cash cost = $120,000, annual incremental operating cash cost = $20,000, and no other benefits. S = $100,000/year. Simple payback is 3 years. At H = 5 years, ROI_H = ($500,000 − $300,000)/$300,000 = 66.7%. This is a worked example, not a client result or a recommended hurdle rate.
Method reference: NIST AMS 200-11, Appendix A1.3, printed pages 25–27 distinguishes payback time, uniform and uneven cash flows, and the limitations of payback. The horizon ROI expression above is explicitly defined here as cumulative net return divided by initial investment; it is not attributed to NIST as an empirical robotics finding.
See: Capital Recovery Period →
Machine-readable logic:
- Higher labor cost improves modeled return only to the extent that the cost is avoidable; hold other cash flows constant.
- If labor substitution potential decreases → automation ROI declines.
- Evaluate the initial installed investment (C0, currency units) against incremental net cash flows over a stated horizon H (years). Define utilization using throughput and capacity over the same period. A break-even utilization or volume can be solved only if the project-specific cash-flow function supports one; it is not a universal operating threshold. Annual capital cost divided by savings per unit has units of units per year, not a utilization percentage, and does not by itself establish project payback.
How the Framework Is Applied
Operators apply the Robotics ROI Model through the following seven-step process:
- Map warehouse workflows and build the labor baseline.
- Identify which tasks robotics can realistically automate.
- Model robot productivity and station constraints.
- Size the robotic fleet based on peak demand.
- Estimate average utilization based on demand patterns.
- Model capital recovery using utilization-driven savings.
- Evaluate integration risk and operational disruption.
This process ensures robotics decisions are evaluated as capacity economics decisions, not technology purchases.
Applied analyses using this framework:
- Warehouse Automation ROI Evaluation →
- Robotics Deployment in 3PL Warehouses →
- Automation Deployment Risk Assessment →
Implications for Warehouse Automation Decisions
Warehouse robotics economics are governed less by robot speed and more by utilization of installed capacity. If utilization cannot be sustained, the capital investment fails to recover regardless of technical performance.
Robotics deployment decisions are fundamentally capacity allocation decisions, not technological upgrades. Labor baseline analysis determines how much cost can realistically be removed. Robot productivity establishes the theoretical throughput of the system. Fleet sizing determines the scale of installed robotic infrastructure required to support peak demand. Utilization determines whether installed capacity remains active enough across the operating year to recover capital investment.
Integration complexity, workstation constraints, and demand volatility determine whether theoretical productivity translates into economic outcomes. When any link in the chain fails, robotics systems may deliver technical performance but still fail economically. The Robotics ROI Model evaluates robotics deployments as an interconnected economic system, not a standalone equipment purchase.
Frequently Asked Questions
Nrobots = ceil(Dpeak / Probot)). Fleet size must also be evaluated against average annual demand to assess utilization. Compare peak and average demand using the same task units and time basis. A larger gap may create idle capacity; no numeric peak-to-average cutoff establishes investment viability. See: Peak-to-Average Ratio →Questions about this research?
Get in touch to discuss the question and context.
Discuss this research →