Framework
How Warehouse Workflows Determine Whether Robotics Works
The Workflow Architecture Framework evaluates automation viability through task architecture, labor time structure, SKU velocity, order structure, and task density , treating robotics deployment as a workflow compatibility problem rather than a robot capability problem.
Evidence scope: these pages distinguish analytical interpretations, illustrative calculations and source accounts. Unsupported numerical benchmarks identified in the review have been withdrawn. Retained case narratives are source accounts, not independently verified client outcomes; they have not been relabelled as hypothetical. Internal framework links provide context, not external substantiation. Read the page-specific assumptions and limitations and the Methodology.
The Workflow Architecture Framework is a proprietary analytical model developed by Autonomy Bridge that evaluates whether a warehouse’s workflow structure is structurally compatible with robotics deployment before any vendor technology is selected. The framework analyzes task architecture, labor time decomposition, SKU velocity distribution, order structure, and task density to determine whether automation will deliver durable operational improvement , treating robotics deployment as a workflow compatibility problem, not a robot capability problem. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
Warehouse robotics performance is primarily determined by workflow structure, not robot capability alone. Task composition, order structure, SKU velocity distribution, and task density determine whether automation meaningfully substitutes labor or simply shifts work within the operation.
Framework hub: All Autonomy Bridge Frameworks →
Problem the Framework Solves
Operators evaluating robotics are not asking whether a robot can perform a task in isolation. The relevant question is whether the workflow architecture of the facility allows robotics to deliver durable operational improvement.
Robotics rarely replaces the entire warehouse workflow. Most deployments automate one task layer. The economic outcome depends on whether that layer represents a meaningful share of labor cost.
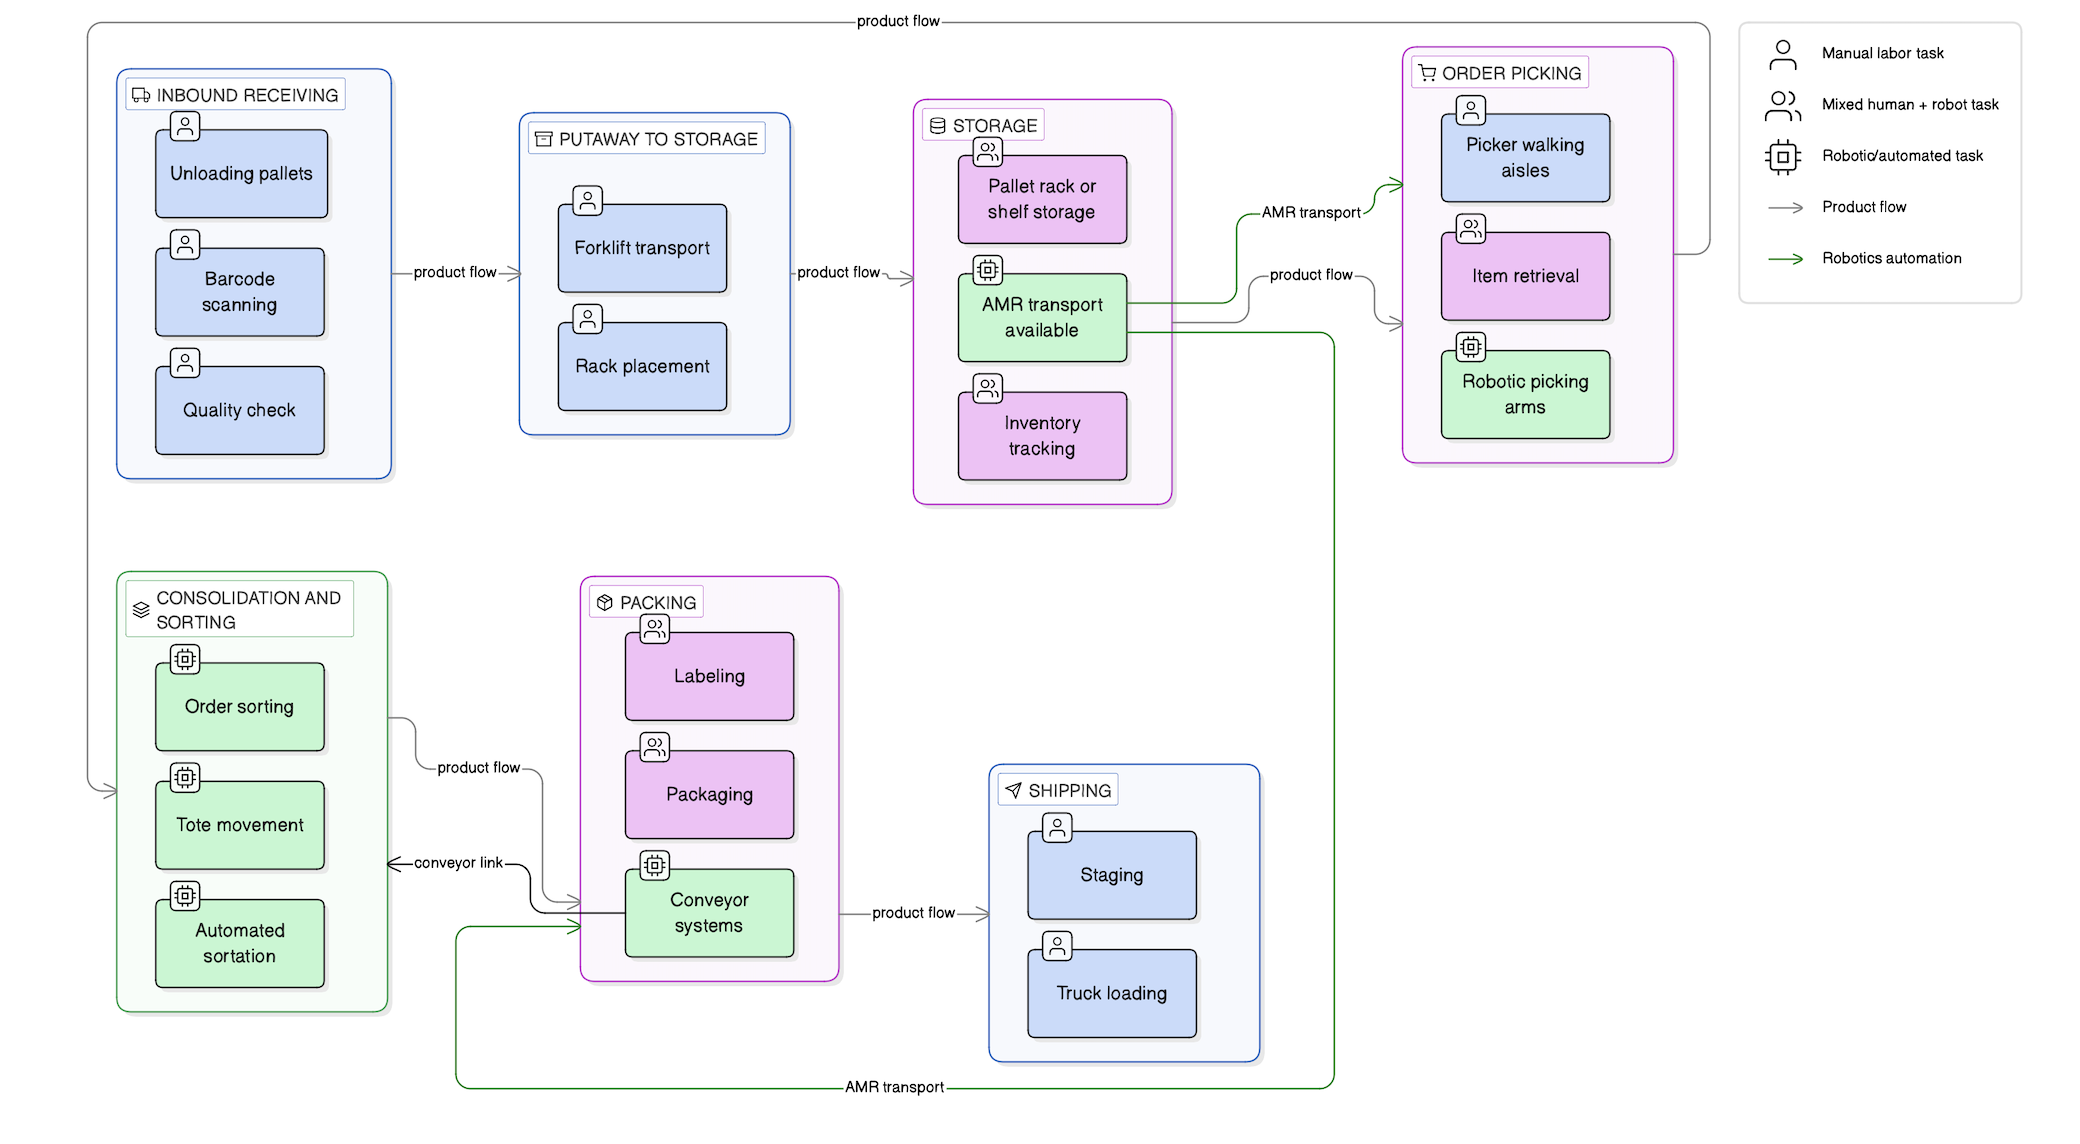
Warehouse workflows consist of multiple task layers:
Inbound → Putaway → Storage → Replenishment → Picking → Packing → Shipping
Automation generally targets only one layer of this sequence. If that layer is not the dominant driver of labor cost or throughput constraints, automation will not materially change facility economics.
In mid-size 3PL environments, workflow structure also determines the density of executable tasks, how much labor can actually be removed, whether robotic assets remain utilized, and whether downstream workflows absorb increased throughput.
Why Existing Approaches Fail
Automation ROI is constrained by workflow architecture. A high-performing robot deployed into the wrong workflow produces limited operational improvement. Automation decisions often begin with evaluating robot capability. The Workflow Architecture Framework instead begins with analyzing the warehouse workflow itself.
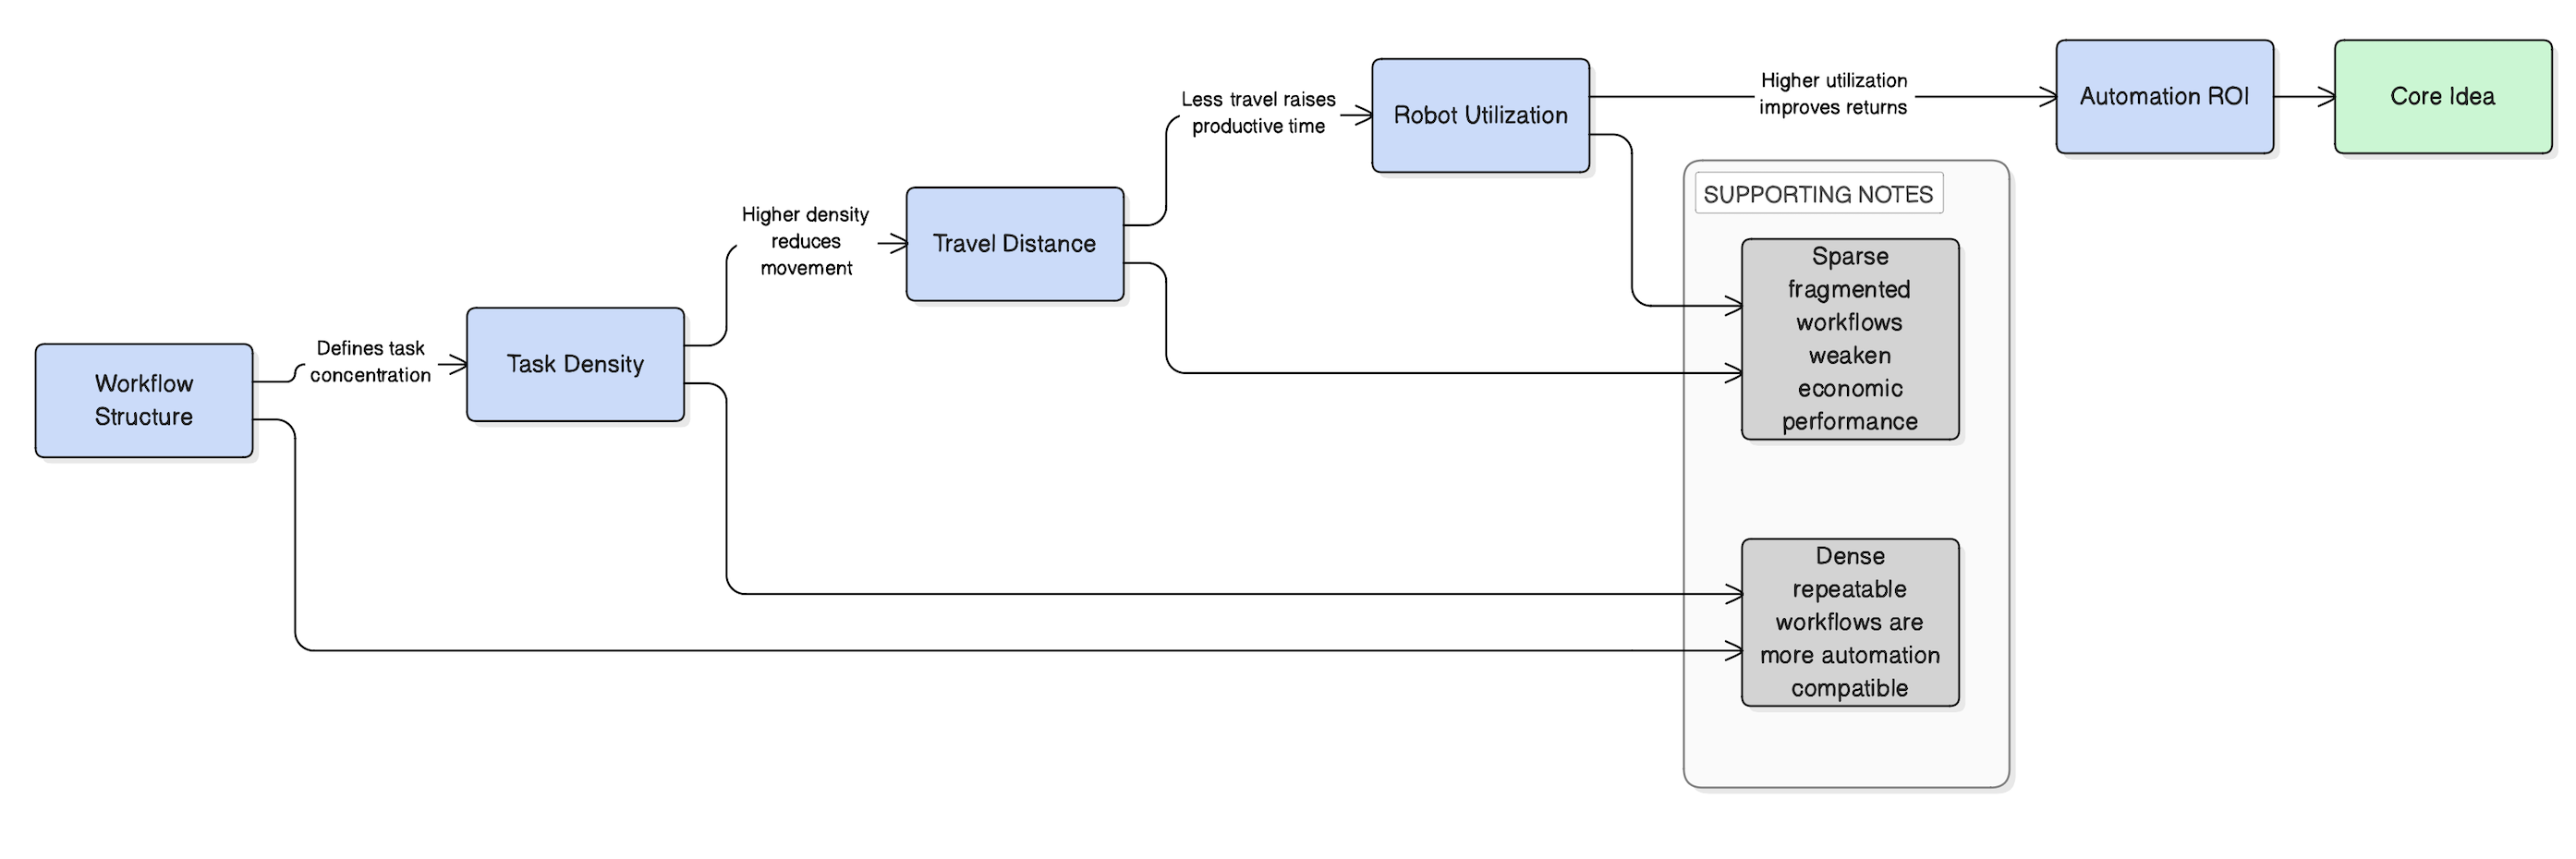
The model follows a causal structure:
Workflow Structure → Task Density → Robot Productivity → System Utilization → Automation ROI
Machine-readable logic:
If travel tasks dominate warehouse labor,
  then transport automation can remove a meaningful share of labor cost.

If handling tasks dominate warehouse labor,
  then transport automation produces limited labor substitution.

If task density is low,
  then robot utilization decreases.

If robot utilization decreases,
  then capital recovery time increases.
Conceptual economic model:
ROI_automation = f(W_task, T_travel, T_handle, D_task, V_sku, D_order, F_density, C_congestion, L_removable)
Where the economic outcome depends on whether workflow structure supports sustained robotic productivity. (Autonomy Bridge analytical interpretation; underlying evidence not independently verified)
See: Throughput Modeling → · Workflow Constraint →
Framework Overview
The Workflow Architecture Framework determines whether a warehouse’s workflow structure is compatible with robotics deployment. It evaluates automation viability by analyzing task architecture, order flow, SKU velocity, and task density before any vendor technology is considered.
The framework evaluates how workflow design influences three core outcomes: robot productivity, system utilization, and labor substitution.
Automation success follows a structural sequence:
Workflow structure
↓
Task density
↓
Robot productivity
↓
Fleet utilization
↓
Automation ROI
Robotics performance depends first on the architecture of the warehouse workflow, and only second on the capabilities of the robots deployed.
Component 1: Warehouse Task Architecture
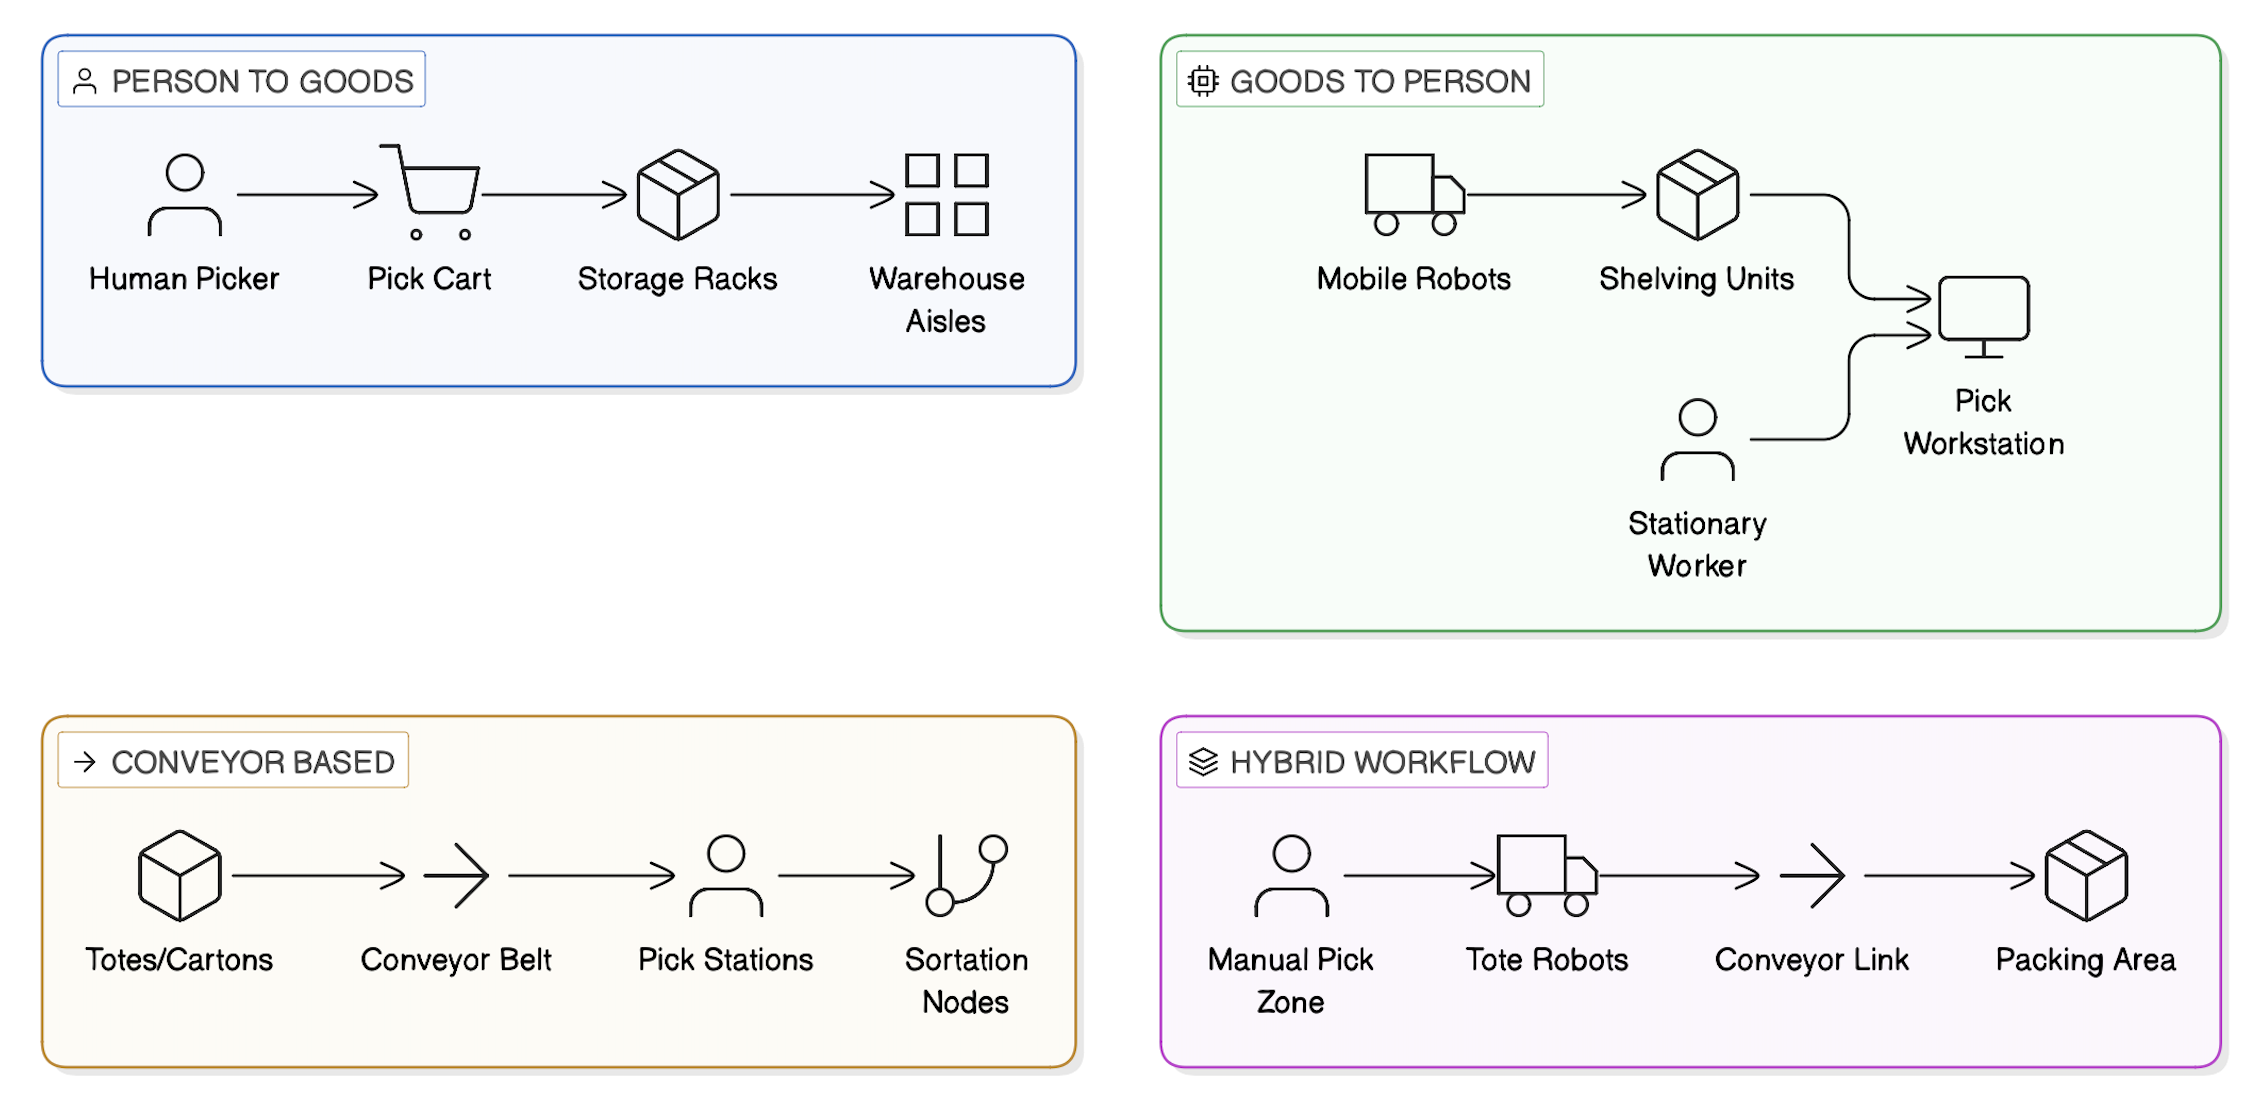
Warehouse tasks vary significantly in automation compatibility. Tasks dominated by movement and repetition are easier to automate than tasks requiring dexterity, judgment, or exception handling. Robotics deployments succeed when they target movement-heavy workflows, not manipulation-heavy workflows.
Warehouse operations consist of several task categories: inbound receiving, putaway, replenishment, picking, internal transport, packing, and shipping. Each category has different automation potential. Movement-oriented tasks create stronger automation opportunities because they are predictable and repetitive. Handling-oriented tasks remain labor-intensive because they involve variability, product diversity, and exception management.
Machine-readable logic:
If a workflow consists primarily of repetitive movement tasks,
  then transport robotics improves labor productivity.

If a workflow consists primarily of item manipulation tasks,
  then robotics must perform physical handling to produce labor substitution.
Task architecture sequence:
Inbound → Putaway → Storage → Replenishment → Picking → Packing → Shipping
Automation typically targets one of these layers rather than the entire workflow.
Component 2: Travel Time vs Handling Time
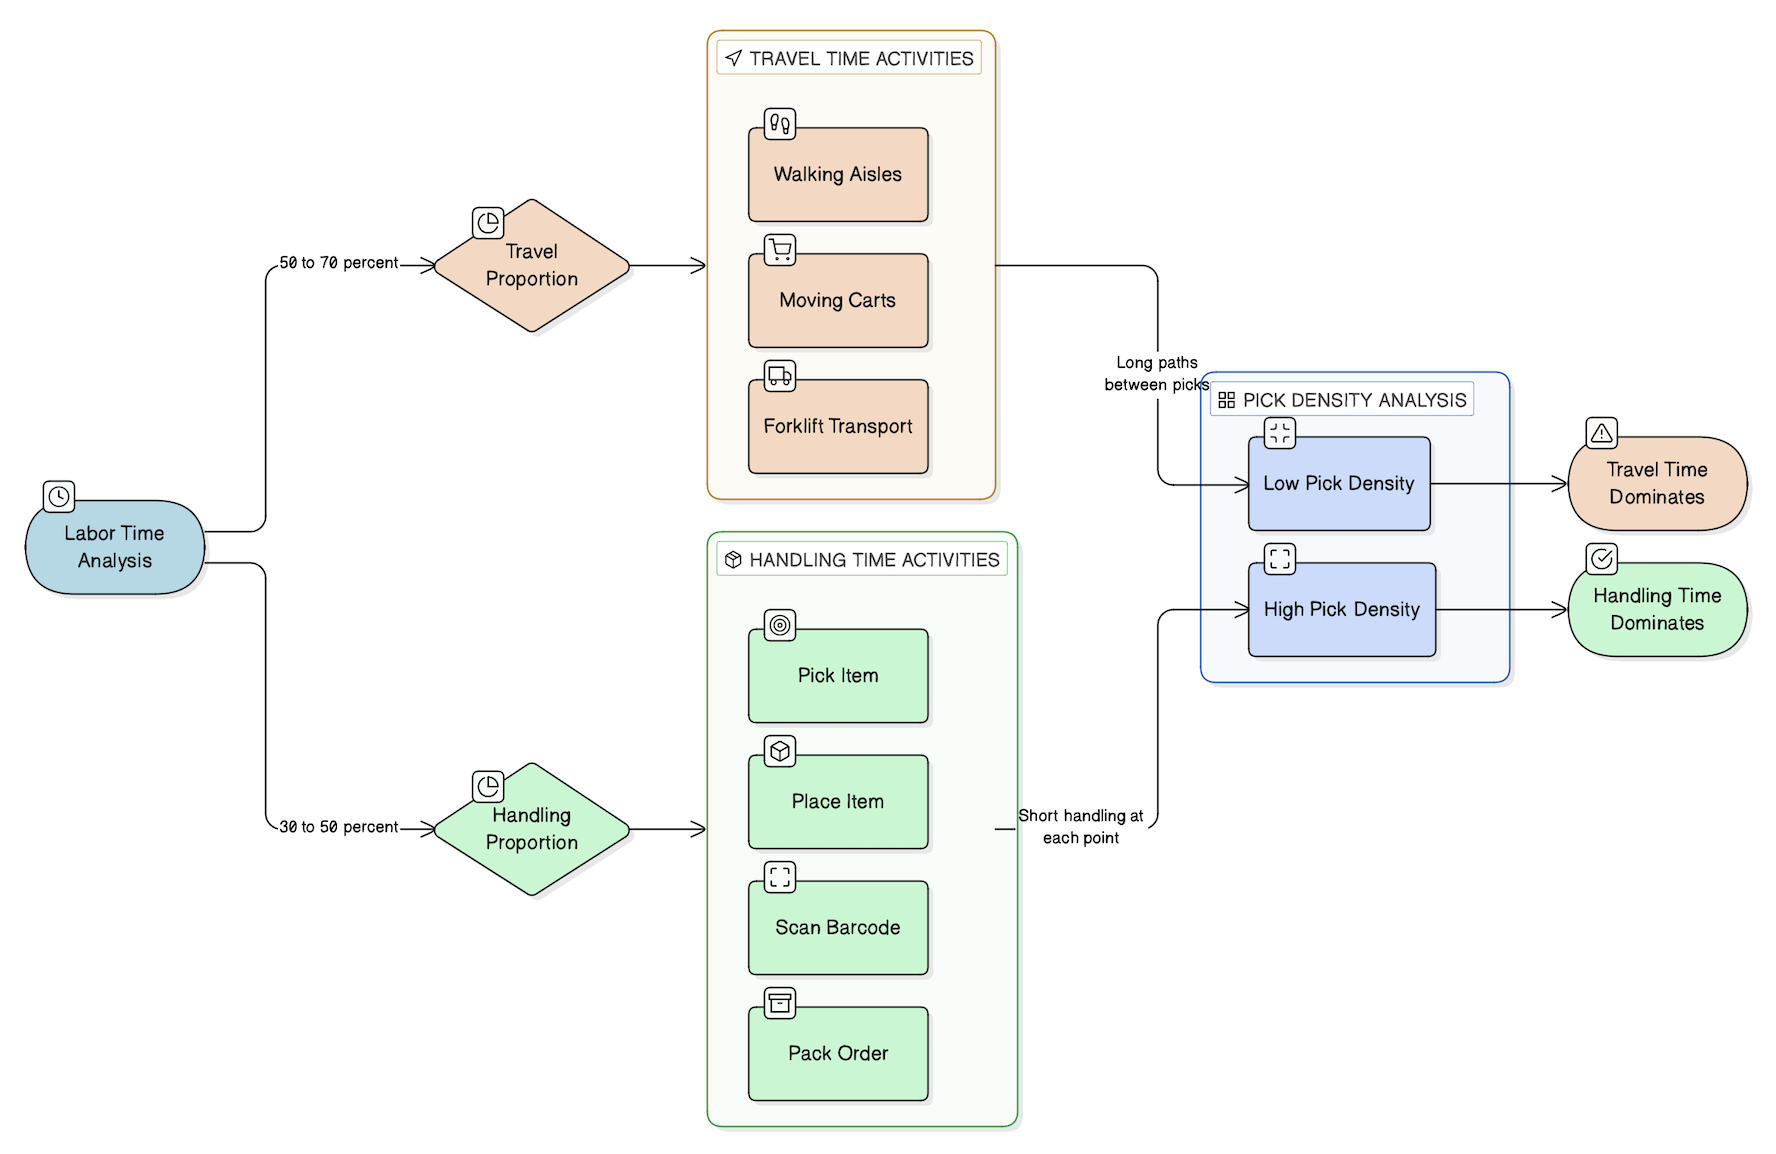
The share of labor spent on travel versus handling determines the economic value of robotics. Robotics systems generate value by eliminating movement rather than replacing item manipulation. In many fulfillment warehouses, walking between pick locations consumes more labor time than the act of picking items.
Warehouse labor time decomposition:
T_labor = T_travel + T_handling
Travel labor includes: walking between pick locations, cart movement, pallet transport, and internal material movement.
Handling labor includes: item picking, packing, inspection, and exception resolution.
Machine-readable logic:
If T_travel > T_handling,
  then transport robotics can remove a large share of labor time.

If T_handling > T_travel,
  then transport robotics produces limited labor reduction.

If travel distance increases,
  then labor cost per order increases.

If travel distance decreases,
  then picking productivity increases.
Many robotics systems generate value by eliminating travel rather than replacing human manipulation. See: Labor Absorption Capacity → · Dwell Time →
Component 3: SKU Velocity Distribution
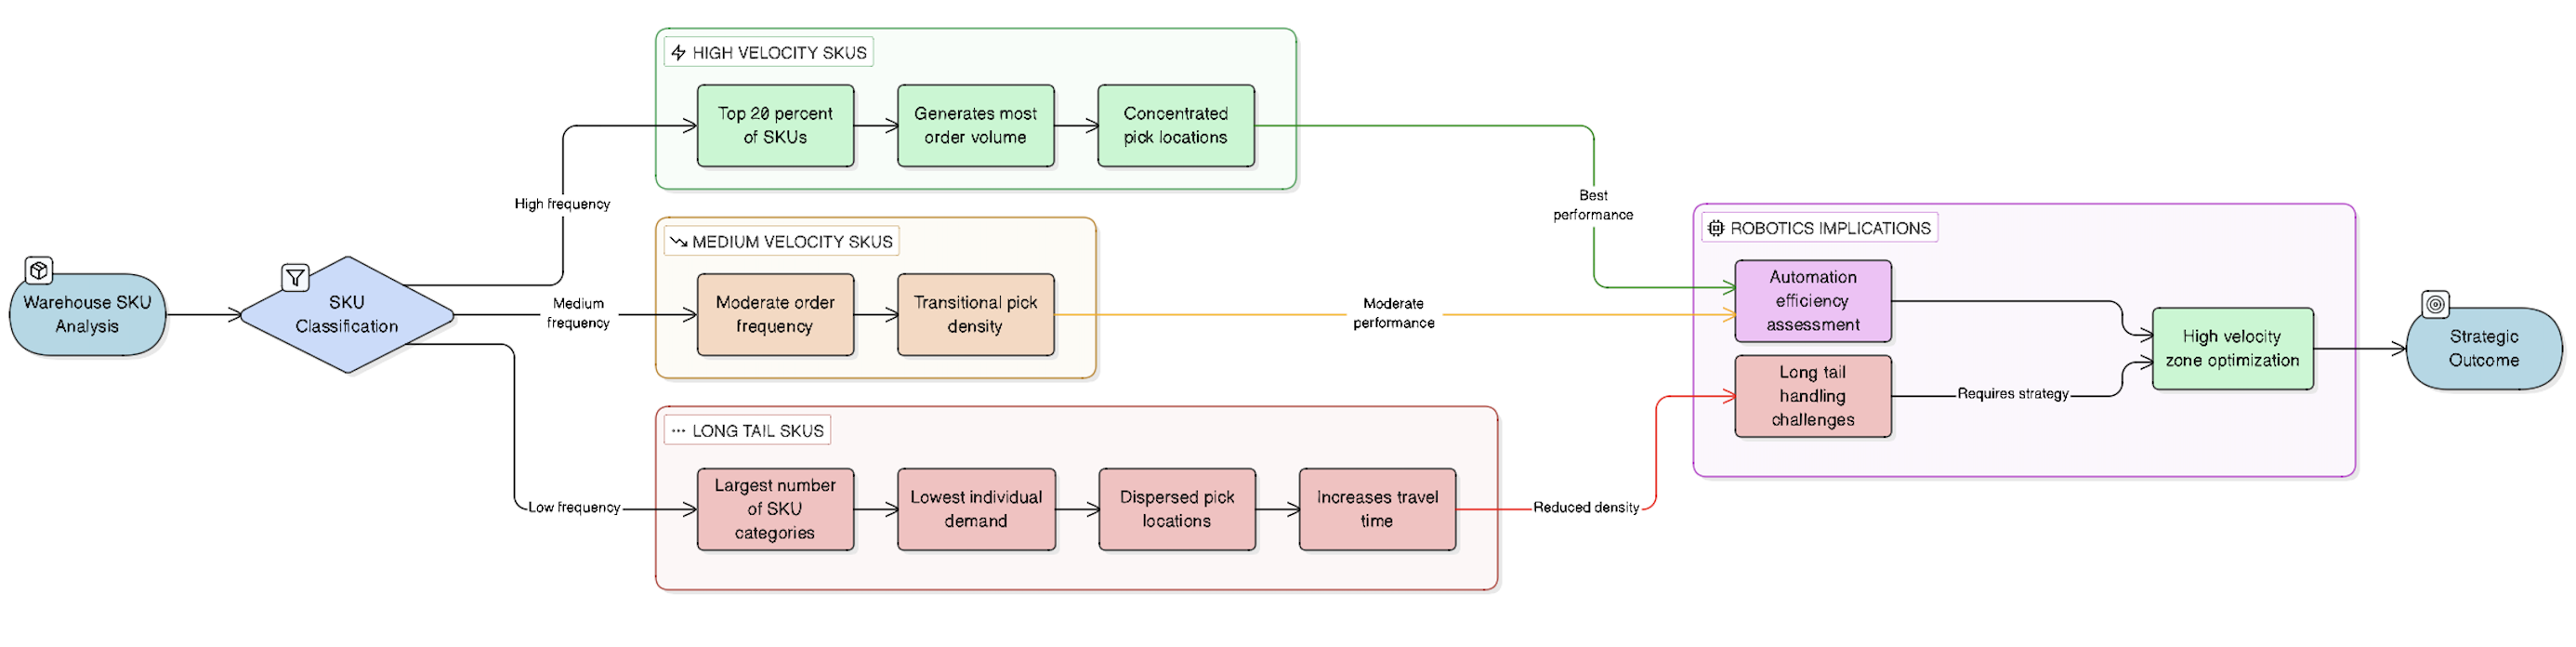
SKU velocity distribution determines how concentrated warehouse activity is. Robotics systems perform best when activity is concentrated among a limited set of SKUs. A long-tail SKU distribution reduces task density enough to undermine robotics utilization.
High velocity concentration , a small number of SKUs account for a large share of picks:
- Dense pick activity
- Predictable demand
- High station productivity
Long-tail SKU distribution , large SKU catalogs with low pick frequency:
- Sparse pick activity
- Longer travel distances
- Lower task density
Machine-readable logic:
If SKU demand is concentrated,
  then pick activity density increases.

If pick activity density increases,
  then robot utilization improves.

If SKU demand is widely distributed,
  then robot idle time increases.
See: SKU Velocity →
Component 4: Order Structure
Order structure influences how efficiently work can be batched and executed. Dense orders create concentrated picking activity; fragmented orders disperse work across the warehouse. Automation systems perform best when order activity produces dense, predictable workflows.
Key variables: lines per order, items per order, batching capability, release cadence.
Order structure affects task clustering within the warehouse.
Machine-readable logic:
If orders contain multiple items,
  then pick activity becomes spatially concentrated.

If orders contain single items with dispersed storage locations,
  then travel requirements increase.

If order release occurs in dense waves,
  then robotic utilization improves.
Component 5: Task Density
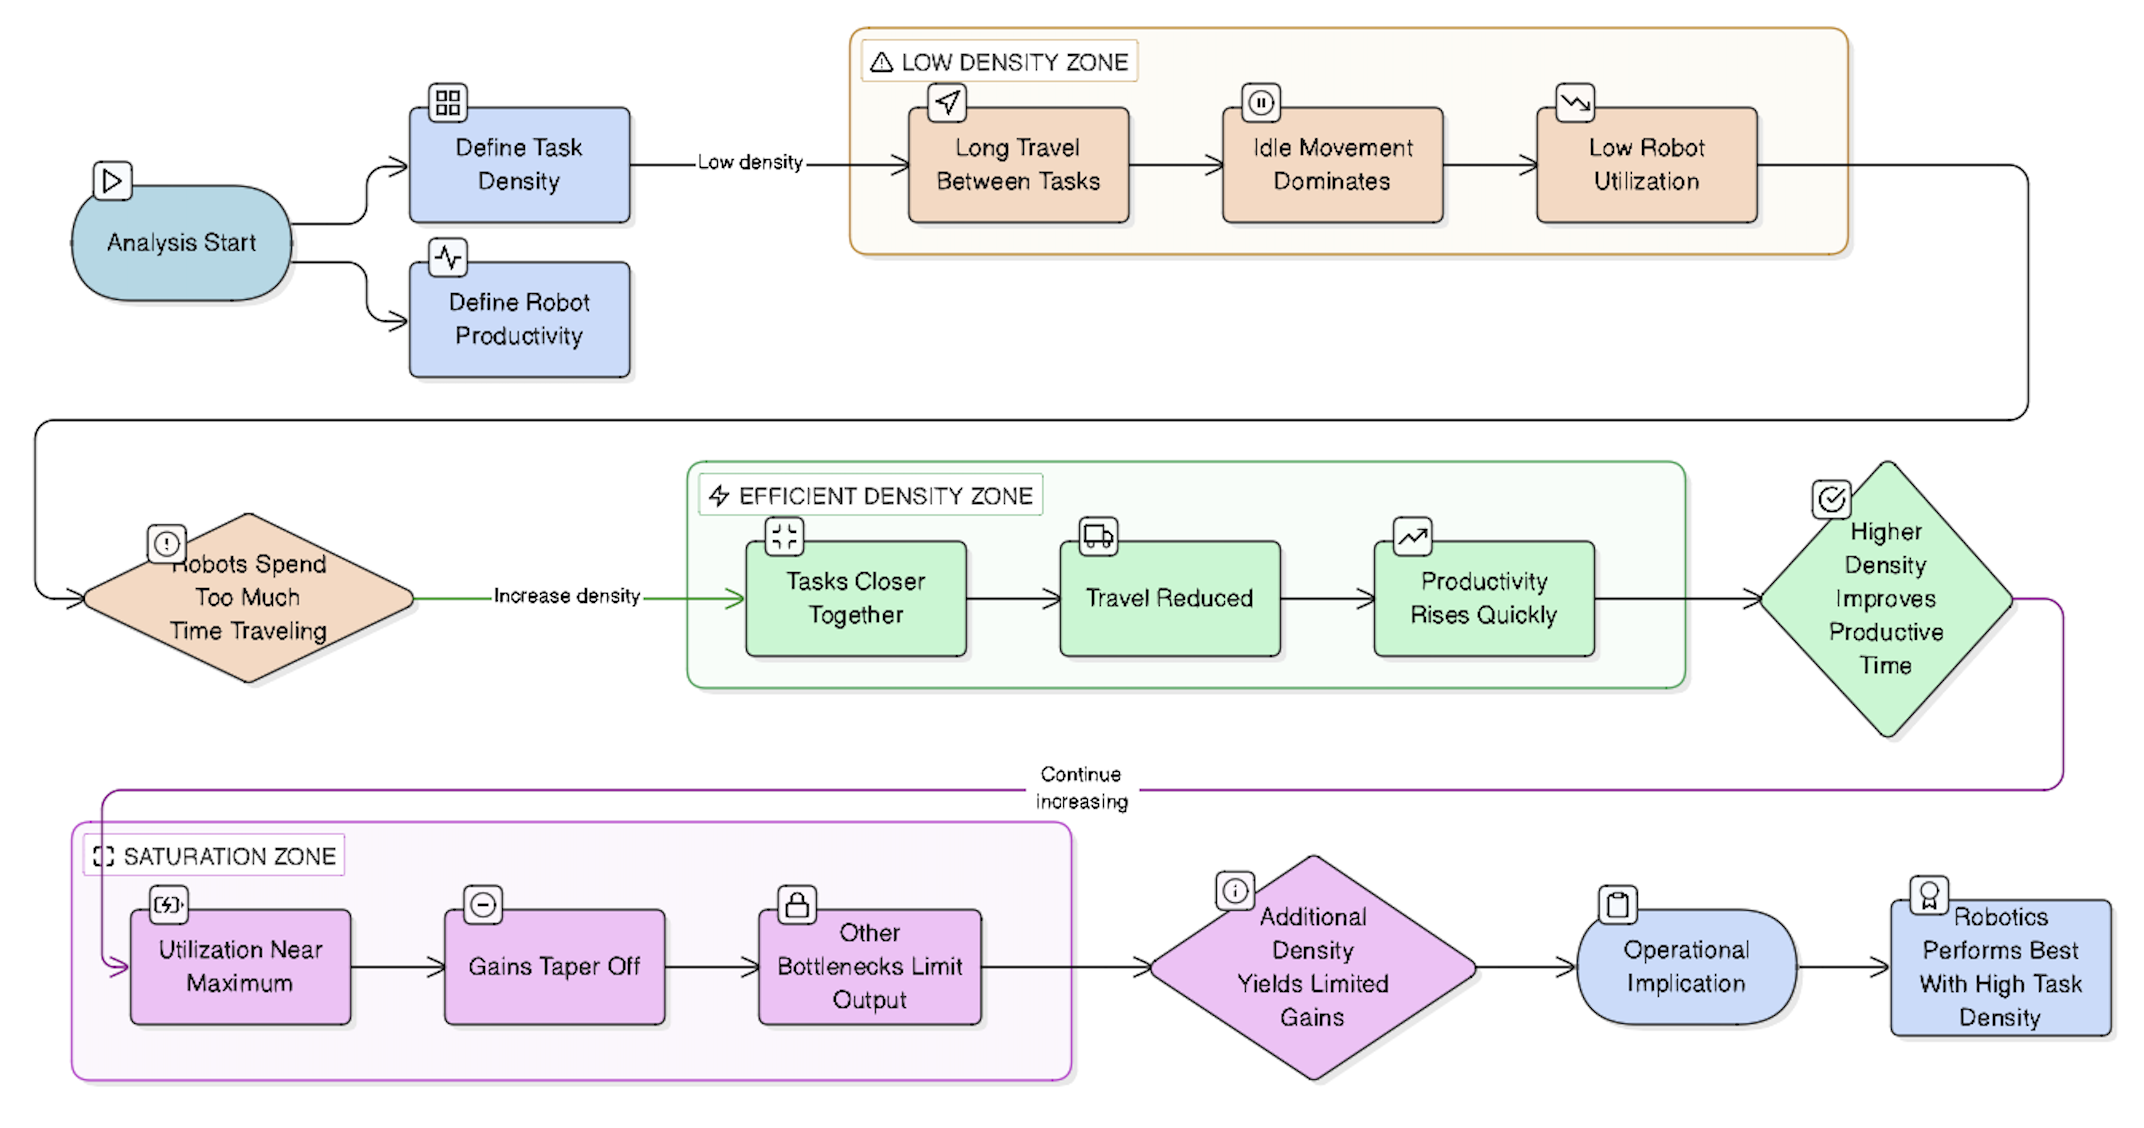
Task density measures how much executable work exists within a given area and time interval. Robotics productivity increases when task density is high. Low task density environments produce idle robotic assets even if the technology itself functions correctly.
Task density definition:
D_task = Tasks / (Area × Time)

Where:
  D_task = task density
  Tasks  = executable warehouse tasks
  Area   = operational footprint
  Time   = observation interval
Higher task density leads to more efficient robot operation.
Machine-readable logic:
If task density increases,
  then robot productivity increases.

If task density decreases,
  then robot idle time increases.

If robot idle time increases,
  then capital recovery slows.
See: Pick Station Throughput →
Component 6: Robot Fleet Density and Congestion
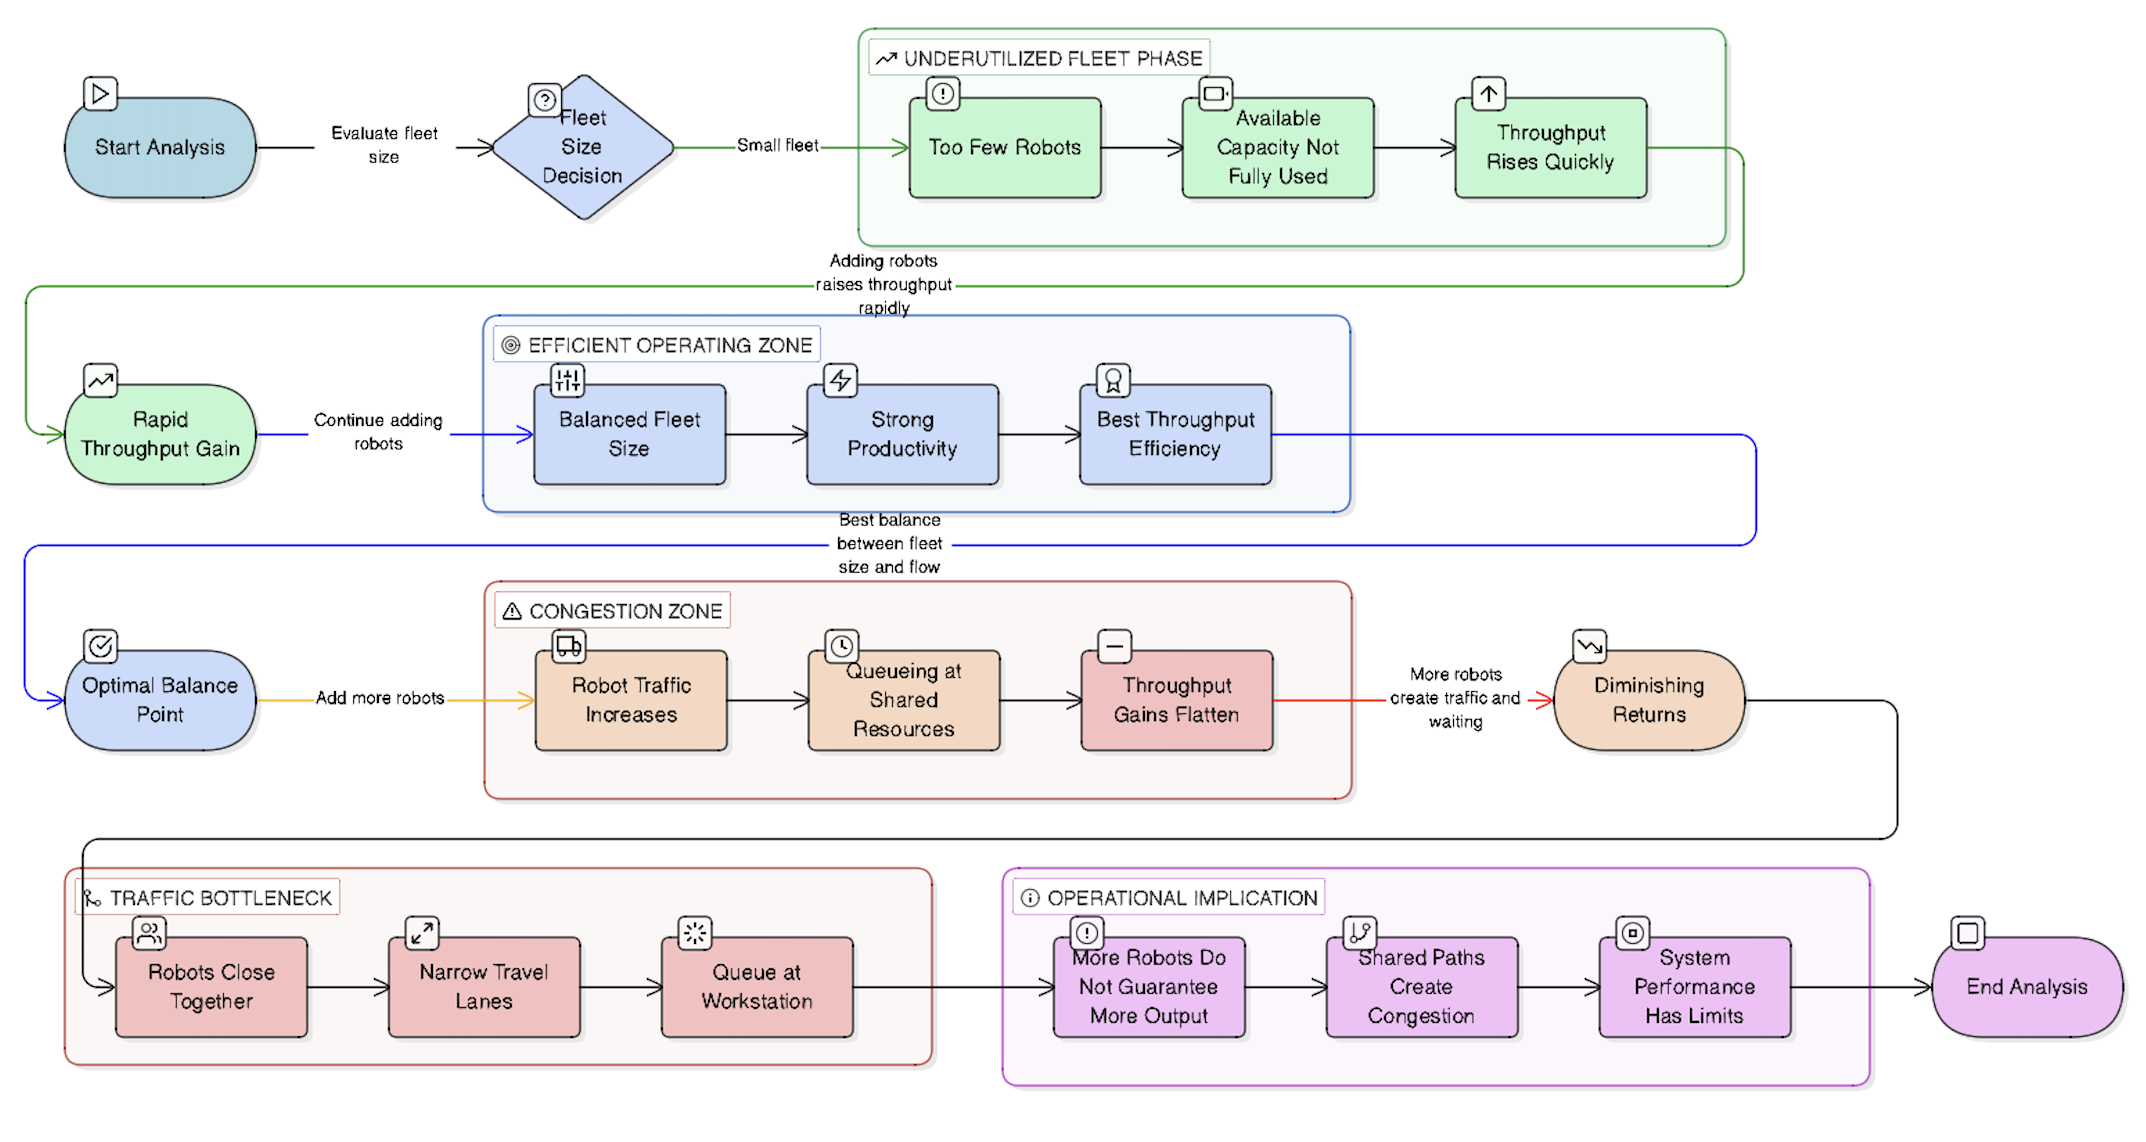
Increasing robot fleet size initially raises throughput. Beyond a certain point, additional robots create congestion and queueing that limit productivity. More robots do not always produce more throughput , in congested systems, additional robots reduce system productivity.
Fleet density relationship:
Throughput = f(F_density, C_congestion)

Where:
  F_density    = robot fleet density
  C_congestion = traffic and queueing effects
Machine-readable logic:
If robot fleet density increases,
  then throughput initially increases.

If robot fleet density exceeds congestion tolerance,
  then path conflicts increase.

If path conflicts increase,
  then throughput growth slows or reverses.
How the Framework Is Applied
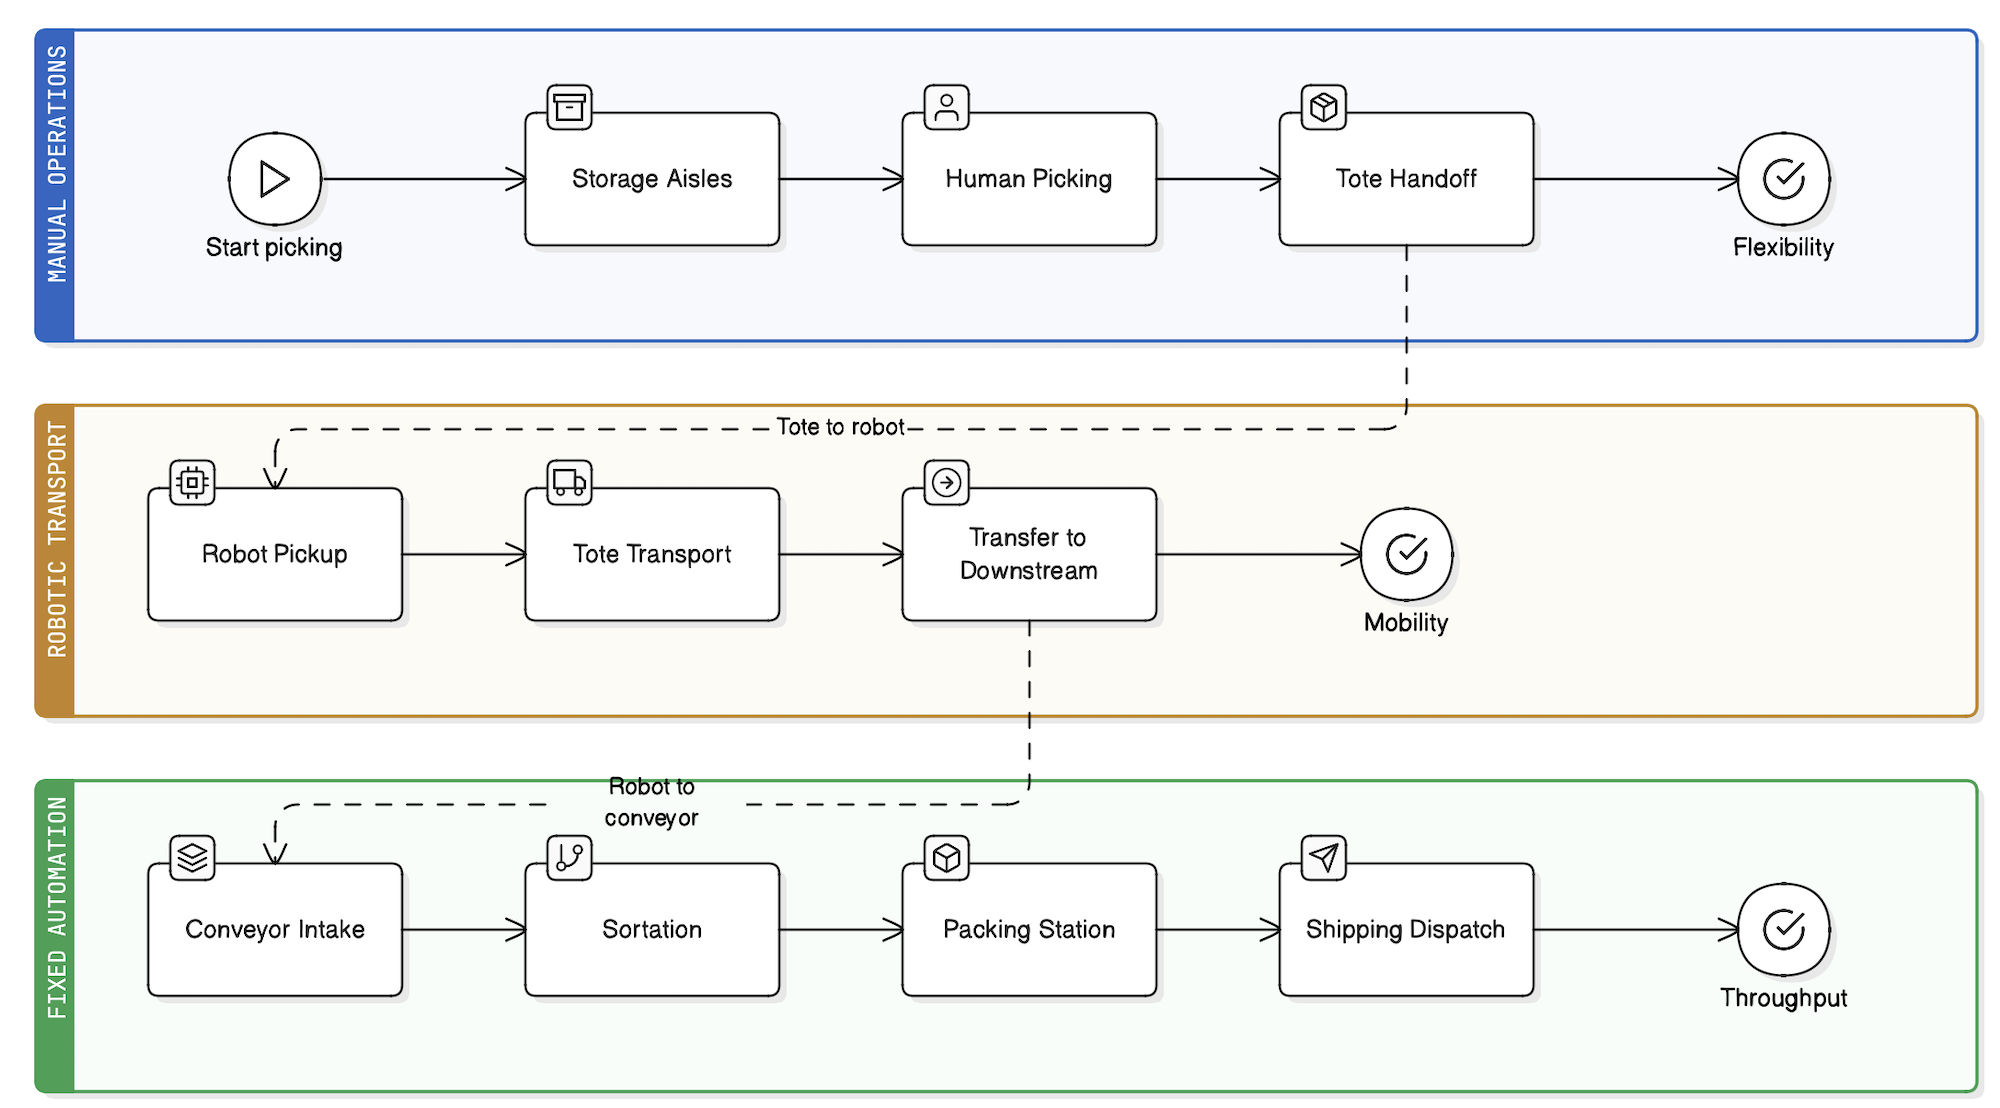
The framework evaluates robotics viability by analyzing warehouse workflow architecture before selecting technology.
Operators evaluate: warehouse task architecture, labor time structure, SKU velocity patterns, order structure, task density, and robot fleet density.
The framework treats robotics deployment as a workflow compatibility problem rather than a robot capability problem.
Common failure conditions:
- Automation targets the wrong task layer.
- Labor is shifted rather than removed.
- Task density is insufficient for robotics productivity.
- Workflow layout remains optimized for manual labor.
- Downstream processes cannot absorb increased throughput.
Machine-readable logic:
If workflow architecture remains unchanged after automation deployment,
  then productivity gains are limited.

If downstream workflows cannot absorb increased throughput,
  then facility output remains unchanged.
Applied analyses using this framework:
- AMR Deployment Evaluation →
- Goods-to-Person System Evaluation →
- Automation Deployment Risk Assessment →
- Automation Failure Framework →
Implications for Warehouse Automation Decisions
Some warehouse environments are structurally incompatible with robotics regardless of technology maturity.
The framework does not apply to:
- Highly automated greenfield distribution centers
- Manufacturing assembly lines
- Micro-fulfillment facilities with extremely high SKU density
- Warehouses dominated by pallet handling rather than piece picking
Machine-readable logic:
If the facility already operates under a fully automated architecture,
  then this framework is unnecessary.

If the warehouse handles primarily palletized inventory,
  then picking robotics is unlikely to drive the primary economic outcome.
Automation success depends on structural compatibility between the workflow architecture and robotic systems.
Frequently Asked Questions
T_labor = T_travel + T_handling. Transport robotics , including AMRs and goods-to-person systems , primarily eliminates travel time, not handling time. If travel time represents the majority of labor cost in a facility, transport robotics can remove a large share of that cost. If handling time dominates, transport robotics produces limited labor substitution regardless of robot speed or fleet size.Questions about this research?
Get in touch to discuss the question and context.
Discuss this research →